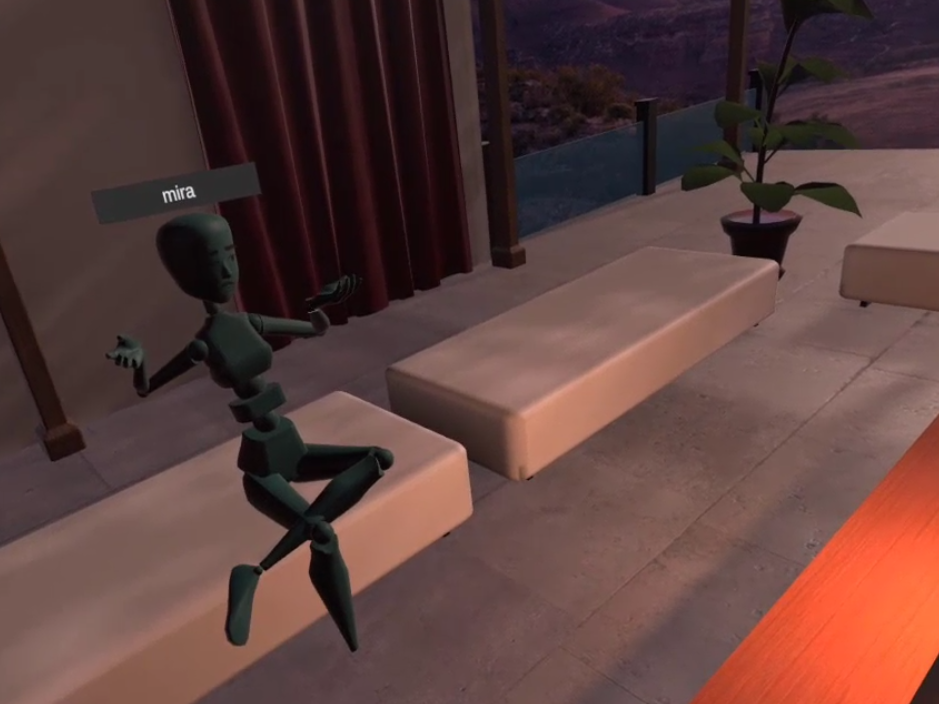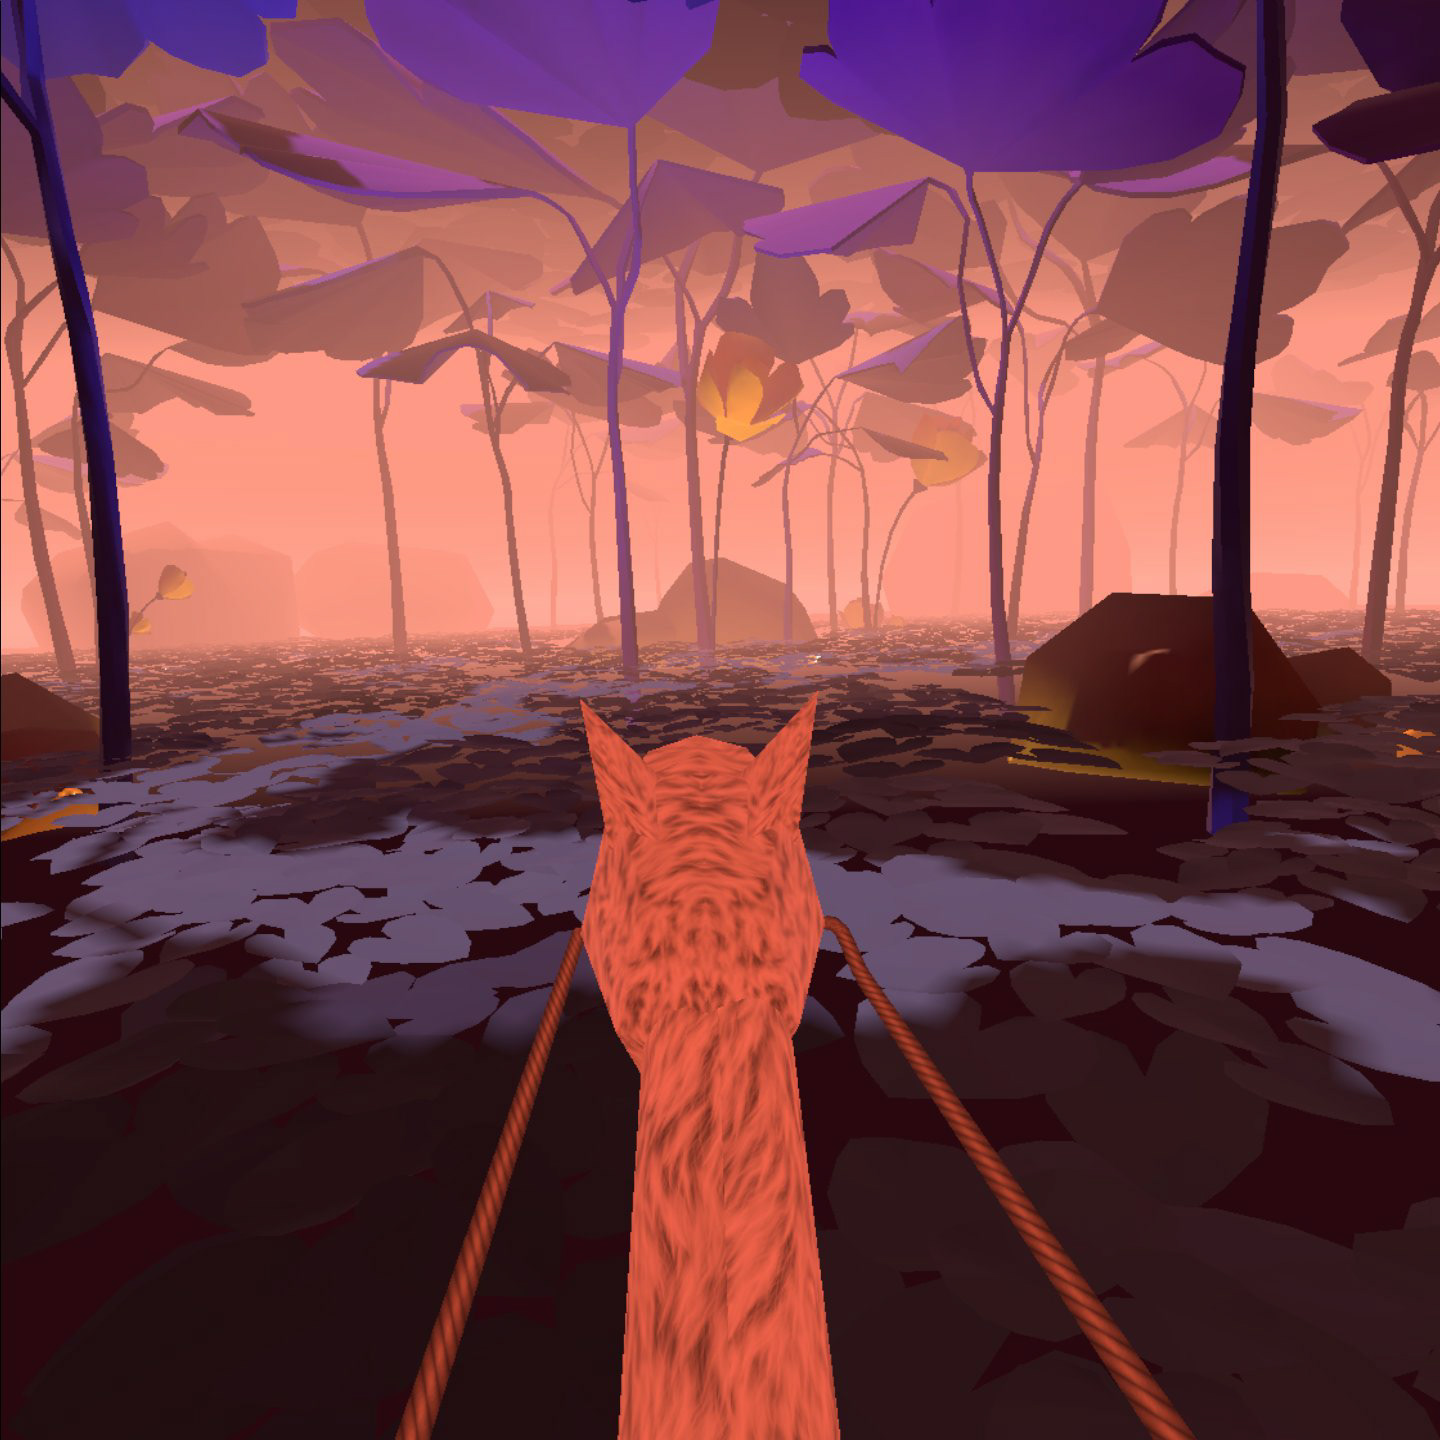
In the winter and spring of 2023 we conducted some experiments at improving immersion with the aid of haptic feedback. Building upon the work done in the SILvr project we created a multi-user social environment where participants arrived upon a horse-like animal's back, as a rider. The animal, called a “polydon” was controlled by reins. These reins existed in both the virtual and the real world. The reins were made using simple rope and springs (bungee cord) to provide the physical sensation of pulling with increasing resistance to steer the animal and to communicate stop/go as one might with a horse. The environment was designed to be simple but calming and it was a lot of fun to meet friends in the environment and just hang out and chat together. We expect to continue this research as the haptic feedback and controlling a virtual animal seems very promising for a more immersive experience.
Some results
- Haptic feedback tied to the sensation of influencing a virtual animal greatly increases the sense of immersion and presence.
Primary participants
- Amon Ferri, Anna Wu
Advisors: James Mahoney, Michael Cohen